In build · Oct 2026 → Present
Twinky
A desk robot
with opinions.
A palm-sized, sassy open-source desk robot: it rolls around, tracks you with a tilting head and two glowing eyes, roasts you out loud, remembers what you told it, and never drives off the desk.
Highlights
The problem.
Twinky is a desk robot with opinions. It should hear you, see you, answer out loud, remember what you told it and roll around — and never drive off the edge — with its brain on a $100 board.
It is also the most honest kind of test for the work I like doing. A robot can't be faked with a screenshot; it either rolls to the edge and stops, or it doesn't.
What I built.
The brain is an Orange Pi 5 Pro with an NPU, running speech recognition with Whisper, vision with YOLO, and conversation as a hybrid of Qwen 2.5 running locally and Claude. Alongside it: an ESP32-S3, wheels, a tilting head and two round GC9A01 LCD eyes.
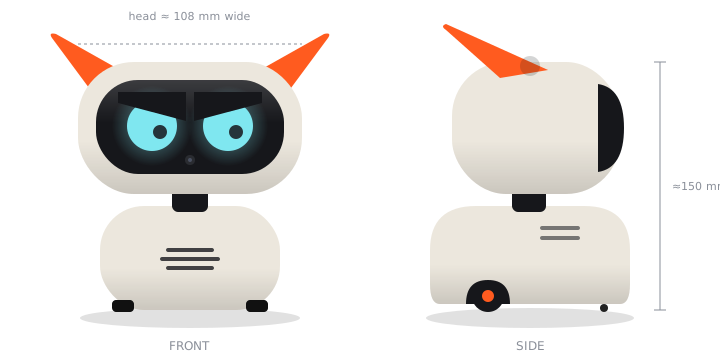
The design is a big head on a small body: a black visor with floating eyes, swept-back ear fins, ivory and signal orange, about 150 mm tall with a head about 108 mm wide.
Parts were ordered in October 2026. Until they arrive, the brain software runs against a simulated body.
Results.
- Parts ordered in October 2026; the brain software runs on a simulated body.
- Front and side concept drawings set the proportions: about 150 mm tall, head about 108 mm wide.
- Nothing has run on the physical robot yet, so there are no measured results to report.
Architecture
How it fits together.
- 01
Mic · camerainputs
- 02
Orange Pi 5 ProNPU · Whisper · YOLO
- 03
ConversationQwen 2.5 local · + Claude
- 04
ESP32-S3microcontroller
- 05
Wheels · headtilt
Eyes2× GC9A01
In hindsight
Too early for hindsight, so this is a promise instead: the same rules as the projects above. The page will show what the robot actually does on a real desk — including how often it stops at the edge — and the concept render comes down when there is a photo to replace it.
Tech specs.
- Type
- Project
- Where
- Personal
- When
- Oct 2026 → Present
- Duration
- 1 mo
- Status
- In build
- Stack
- Orange Pi 5 ProESP32-S3GC9A01WhisperQwen 2.5ClaudeYOLO
- Caveats
- Concept render, not a photo. Parts were ordered in October 2026; the brain software runs on a simulated body, and nothing has run on the physical robot yet.